


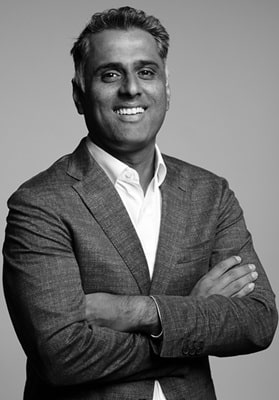
A robot may work perfectly in a lab, but taking it to a real farm is a different test altogether. In an exclusive interaction with EFY’s Saba Aafreen, Jaisimha Rao of Niqo Robotics discusses the AI, electronics, and engineering required to make agricultural robots reliable in Indian fields.
Q. What problem in Indian agriculture led you to start Niqo Robotics, and how has it evolved?
A. I founded Niqo Robotics in February 2015 to bring robotics to farmers with a clear return on investment (ROI). In India, we identified weeding as a major agricultural challenge. Weeds compete with crops for nutrients, moisture, and sunlight, while farmers largely rely on manual labour or blanket herbicide spraying to remove them. We saw an opportunity for a third approach: using AI, computer vision, and edge computing to identify and eliminate weeds selectively. This approach can help protect crop yields while reducing herbicide use and chemical residue, making weeding a practical application of robotics in Indian agriculture.
Q. Is Niqo Robotics’ core innovation technology-led, business-led, or a combination of both?
A. At Niqo, we believe the core challenge is technical, particularly when building robots that can operate reliably in Indian fields amid dust, rain, heat, and changing conditions. These conditions also place additional demands on sensors and other electronic systems. However, engineering alone does not guarantee adoption. We therefore give equal attention to demonstrating a clear ROI and establishing a viable business model so that these technologies can reach farmers and move beyond laboratory applications.
Q. How does NiqoSense identify an individual plant and act on it?
A. Our robot uses the NiqoSense camera, an all-in-one AI camera that combines an image sensor, ISP, SOM, and actuation board in a single IP67-rated form factor designed for agricultural applications. The image sensor captures raw pixel data, which undergoes processing to account for brightness, blur, and colour variations before AI algorithms analyse successive video frames to distinguish weeds from crops. Once a weed is detected, the system tracks and localises it, allowing the actuation system to spray the target within the required response time. The entire process takes place locally, with the camera capturing, processing, detecting, tracking, and localising a weed before triggering the spray within just 60–90 milliseconds. Integrating the entire technology stack within the camera allows the system to complete detection and actuation within this time.

Q. What processors, sensors, and electronics sit behind the AI camera?
A. We use an Ethernet-based communication architecture in which 12 cameras on each robot connect to a master unit. This setup manages timestamps, health information, and odometry. The NVIDIA SOM sits on a custom carrier board designed to meet its thermal requirements and interface with the image sensors. We also use a specialised ISP device for image and signal processing, while multiple specialised ICs handle communication protocols and high-frequency microchips control the actuation system to trigger the right nozzle at the right time. Integrating these components into a reliable system forms a significant part of our in-house electronics architecture.
Q. What role does power electronics play in the system?
A. Our robots are tractor-mounted and use the tractor for propulsion, eliminating the need for an independent motor-control system. The robot follows the tractor’s speed. Our main power-electronics challenge is therefore to tap and manage power from the tractor, either through a hydraulic or mechanical alternator or directly from its battery. Our main challenge is designing a reliable power-management system that can draw from the tractor’s available power sources.
Q. What are the biggest design challenges in making plant-level intelligence reliable on real farms?
A. Agriculture presents one of the harshest operating environments for physical AI. Cameras and SOMs must withstand dust and heat while operating within thermal limits and avoiding failures or crop misclassification. The hardware must withstand these conditions, with particular attention to SOM overheating and dust accumulation on camera lenses. On the data side, crop type, soil conditions, time of day, days after sowing, and even planting direction can influence how crops and weeds appear. Over the past 10 years, we have learned to combine rugged hardware with diverse software and training datasets that account for these real-world variations.
Q. How do you handle changing field conditions without compromising detection accuracy?
A. Changes in natural lighting can disrupt the detection system, making ambient light one of the biggest challenges in agricultural robotics. We use canopies and internal strobe lights to create controlled lighting conditions, reducing the system’s dependence on natural light. Over the past 10 years, we have found that soil type and colour have little impact on performance. The main factors are the crop’s appearance, its age, and ambient lighting. This consistency in lighting helps maintain detection accuracy across different field conditions.
Q. Why is edge computing essential for agricultural robots?
A. Agriculture often takes place in remote areas where connectivity is poor, making cloud-based processing impractical. Even where connectivity is available, transmitting data to the cloud and waiting for it to be processed introduces latency that does not meet the robot’s operating requirements. Since the robot must detect targets and respond within milliseconds, edge computing is essential for production-grade agricultural robotics. Decisions must be made locally and in real time.
Q. How do you balance AI performance, latency, processing power, and energy consumption?
A. It comes down to core engineering and getting more from less. We use NVIDIA chips, so our engineers optimise the software stack, working with CUDA and PyTorch to reduce processing time while keeping power consumption and thermal performance within limits. The challenge is to maximise chip performance without overclocking the processor or exceeding its thermal limits. This optimisation across the hardware and software stack is a critical part of our engineering work.
Q. What has deploying robots across 220,000 acres taught you about real-world robotics?
A. The experience is entirely different from laboratory testing. In the lab, we cannot always account for practical realities such as where the robot is parked, how it is transported to the farm, or whether it operates for three hours or 18 hours a day. Real-world robotics is a radically different state of affairs from lab robotics, with farmers expecting the reliability of a car despite robots having far more sensors and vulnerability points. The only way to bridge that gap is to test continuously, ship fast, and learn from where the system fails in the field.
Q. How do you test and validate the electronics and AI models before deployment?
A. We follow a structured testing and validation process before delivering robots to customers. First, the robot undergoes laboratory testing, followed by sign-off from the quality control (QC) team. We then test the robot with all its sensors under actual field conditions in India. The QC team conducts a second sign-off before the robot is dispatched to the customer.
Q. What are the biggest hardware constraints today, and where can India’s semiconductor ecosystem help?
A. Right now, memory is our biggest hardware constraint. With AI data-centre demand, something as basic as 256GB solid-state memory has seen long lead times and prices reaching nearly three times last year’s levels, making sourcing difficult. Beyond memory, most of our core ICs and SoCs, including the NVIDIA chip, Lattice FPGA, and ICs, come from outside India. India does not need to begin with 2nm chips; developing high-volume ICs and chips domestically could strengthen robotics supply chains and reduce dependence on imports.
Q. Beyond chips, which electronics capabilities does India need to strengthen?
A. I am quite happy with India’s PCB ecosystem, both in design and fabrication. However, our MEMS sensors are currently imported from Japan, which remains a supply-chain gap. Another clear opportunity is optics engineering, particularly in image-sensor and lens design. These are areas where India can build stronger domestic capabilities and reduce dependence on imports in robotics.
Q. Which semiconductor capability would you most like to see India develop?
A. My top priority would be developing domestic solid-state memory capabilities. Although it may appear to be a basic component, solid-state memory involves highly specialised technology, with only a handful of companies globally possessing deep expertise in its design. This is a critical capability that cannot remain concentrated in just three places around the world. For India, building capabilities in memory design and manufacturing could represent a significant opportunity to strengthen its semiconductor industry and support robotics development.
Q. Which parts of the robotic platform do you manufacture in-house, and what becomes critical as you scale?
A. We currently manufacture all our cameras in-house. We source the individual components from different suppliers, but the cameras are assembled on our dedicated production line in Bengaluru Headquarters, where a specialised production team handles the manufacturing. As we scale, testing is the biggest challenge. We need to ensure that suppliers are delivering error-free chips and components, which means tighter inventory management, stronger quality control of incoming parts, and thorough testing before every system is shipped to a customer. For us, that is what scaling reliably means.
Q. How much of your existing platform can be reused as you expand into new applications?
A. It has taken us 10 years to stabilise our hardware, so much of the existing platform can now support expansion. The focus is shifting towards value engineering. The goal is to simplify the system while retaining the performance needed for applications such as weeding and thinning.
Q. What are Niqo’s next milestones, and how can India help build physical AI for agriculture?
A. At the customer-facing level, we are proving that physical AI can become a commercially viable product with paying customers and sustainable margins. But beneath the robot is a complex stack of electronics and semiconductor components, many of which are imported. As the technology proves itself commercially, our hope is that Indian companies step in to develop indigenous components and fill these supply-chain gaps. If our products can demonstrate that there is a viable market, we believe it can create the incentive to build more of the component-level ecosystem in India.
Q. What would you like to leave our readers with?
A. Thankfully, we are entering a new era of technology. The past 20–25 years have largely been shaped by software, from software services to software-as-a-service (SaaS). However, there is growing recognition that technology must also address the physical world, where atoms matter as much as bytes. Although young engineers may be drawn towards software, hardware is becoming increasingly important. Software and AI tools cannot replace the expertise required to design and build physical systems. The world needs more engineers who understand the physical foundations of technology and can translate that knowledge into hardware.

